
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SoftGripping
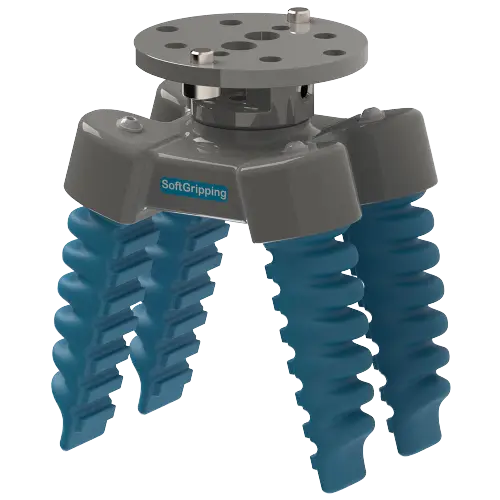
Pneumatic four-finger soft gripper with 14 N gripping force for delicate parts. FDA food-grade silicone fingers grip objects 5–120 mm in size up to 600 g. Weighs 0.4 kg. IO-Link and Modbus TCP control. For food processing, packaging, and lab automation.
SoftGripping Four-Finger Soft Gripper is a pneumatic soft robotic gripper designed for gentle handling of delicate components on collaborative and industrial robot arms in food processing, packaging, and laboratory automation environments.
Soft robotic grippers like the SoftGripping Four-Finger Soft Gripper offer superior adaptability compared to rigid grippers, allowing damage-free manipulation of irregular shapes and fragile items. Common applications include pick-and-place operations for produce, baked goods, proteins, confections, and lab containers such as vials and beakers. The ability to securely handle rectangular, cubic, and lying cylindrical objects differentiates pneumatic soft grippers from rigid alternatives, which are less effective with breakable or oddly shaped items.
Designed for mounting on collaborative and industrial robot arms where low mass is critical, the SoftGripping Four-Finger Soft Gripper (model SG.IN.P.F4.S60.A67.D15.R50) connects easily via IO-Link and Modbus TCP interfaces. Integration is streamlined with pre-configured control units and intuitive software. Suitable for systems requiring precise and gentle automated handling, including robotics from various industrial vendors.
Choose this pneumatic soft gripper when you need damage-free handling of fragile or oddly shaped products. Rigid grippers apply point pressure that can bruise or crack delicate items; soft fingers conform to irregular surfaces and distribute force gently across the product.