
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SoftGripping
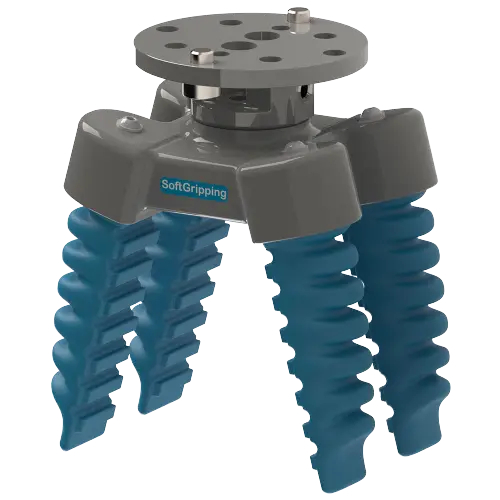
Pneumatic four-finger soft gripper with food-grade silicone fingers for gentle handling of fragile items up to 0.4 kg. Delivers 14 N gripping force and adapts to workpieces 5-120 mm in size. Ideal for food processing, packaging, and pick-and-place applications with IO-Link and Modbus TCP integration.
The SoftGripping SG.IN.P.F4.I60.A67.D15.R50 soft gripper is a pneumatically actuated four-finger end effector designed for robotic handling of delicate and irregular objects in food processing and packaging automation.
Food-grade, FDA-approved silicone rubber fingers enable the SoftGripping SG.IN.P.F4.I60.A67.D15.R50 to securely grasp items such as steaks, seafood, chocolate bars, croissants, beakers, strawberries, apples, figs, mandarins, eggs, and vials. The flexible finger design conforms to varied shapes without causing damage or marking surfaces.
Pneumatic actuation delivers reliable 14 N gripping force and fast cycle times for high-throughput pick-and-place tasks. The gripper handles loads up to 0.4 kg while maintaining gentle contact, making it an optimal choice for sensitive products.
Plug-and-play setup with intuitive configuration tools and pre-configured control units simplifies installation and reduces commissioning time. Universal compatibility allows seamless mounting to many leading industrial robot brands. Connectivity via IO-Link and Modbus TCP ensures easy integration with standard automation controllers.
The SoftGripping SG.IN.P.F4.I60.A67.D15.R50 soft gripper outperforms rigid mechanical and standard pneumatic grippers when handling fragile, irregular, or easily bruised items, minimizing the risk of product damage which is critical in food handling and sensitive material applications.
Choose this four-finger soft gripper when delicate or irregular items need gentle handling without bruising or marking. It adapts to varied shapes naturally, where rigid parallel jaws would crush or slip.