
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SoftGripping
Pneumatic soft gripper with flexible fingers that conform to delicate and irregular shapes, delivering gentle handling without damage. Weighs 0.6 kg, mounts to standard end-of-arm tooling, and integrates via IO-Link and Modbus TCP for reliable performance across changing production environments.
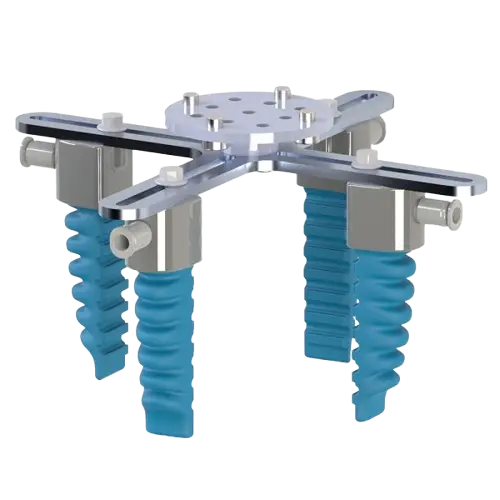
SoftGripping Centric Gorilla Finger Actuator is a pneumatic soft gripper robot end effector designed for handling delicate or irregularly shaped parts in industrial automation.
Manufactured by SoftGripping, the Centric Gorilla Finger Actuator is part of the soft gripper series tailored to applications where traditional rigid grippers may cause surface damage or fail with complex geometries. This end effector employs soft gripping technology, using pneumatically driven silicone or compliant materials to conform to parts without marring the surface. The actuator is ideal for manufacturing, pick and place, packaging, and electronic assembly where part protection and gripping adaptability are essential.
The SoftGripping Centric Gorilla Finger Actuator connects with standard robot interfaces and most industrial control systems, supporting protocols such as IO-Link and Modbus TCP. Custom mounting bases are available, including aluminum or bent plate options, allowing adaptation to specialized equipment or setups. The actuator integrates smoothly as an upgrade or direct fitment to existing end effector tool changers.
This pneumatic gripper is recommended for engineers specifying soft grippers for changing product lines, prototyping, and automation tailored to sensitive or uniquely shaped objects. Common uses include robotic handling in manufacturing where product geometry varies and reliable soft gripping is needed without complex reprogramming or mounting changes.
The Centric Gorilla Finger Actuator stands out from rigid end effectors by preventing part damage and offering flexible geometry adaptation, while delivering higher versatility compared to fixed-shape grippers in the SoftGripping family.
The Centric Gorilla Finger Actuator uses pneumatic soft silicone construction to grip sensitive or irregularly shaped parts without surface damage, making it the choice over rigid parallel grippers or vacuum systems when part geometry varies or surface protection is critical.