
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SoftGripping
Pneumatic soft gripper for delicate and irregular parts. Weighs 0.6 kg, mounts to any end-of-arm tool, integrates with IO-Link and Modbus TCP.
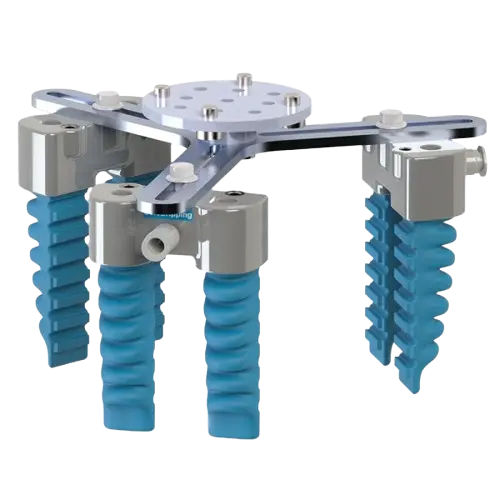
The SoftGripping Centric Gorilla Finger Actuator Soft Gripper is a pneumatic soft gripper designed for collaborative robot and industrial automation applications that require delicate object handling and conformable gripping of sensitive or uniquely shaped items.
The SoftGripping Centric Gorilla Finger Actuator Soft Gripper utilizes advanced soft pneumatic actuator technology to apply uniform, gentle force across irregular or fragile surfaces. Its flexible construction helps reduce risk of damage compared to rigid grippers, supporting safe handling in collaborative environments. Custom mounting bases can be fabricated from aluminum or formed plate for unique setups. For full compatibility details, refer to the SoftGripping end effectors category.
This pneumatic soft gripper excels in food, electronics, and pharmaceutical industries where sanitary handling and adaptability are critical. Common use cases include pick-and-place of fragile produce, automated packaging of sensitive components, and handling of non-uniform laboratory items. Its compliance makes it a strong alternative to traditional rigid grippers for damage-prone or irregular parts.
The Centric Gorilla Finger Actuator is a pneumatic soft gripper designed for fragile and non-uniform objects, where traditional rigid parallel or two-finger grippers risk crushing or slipping. Choose this when conformable grip and gentle uniform force matter more than speed or precision on rigid geometries.