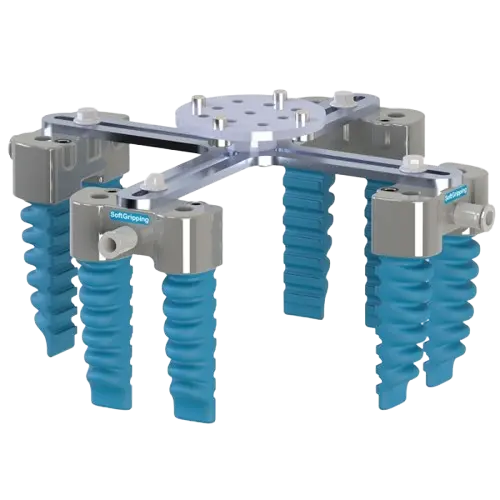
Product Overview:
SoftGripping Centric Gorilla Finger Actuator is an industrial pneumatic soft gripper designed for robots and automation systems handling delicate or irregularly shaped parts in sectors such as food, electronics, and packaging.
- Weight: 0.8 kg
- Interfaces: IO-Link, Modbus TCP
Features:
- Compliant soft actuator fingers conform to a wide range of geometries, making it ideal as a pneumatic soft gripper for delicate parts and irregular shapes.
- Supported by SoftGripping, with custom mounting bases available in aluminum or bent plate for flexible integration into industrial robot EOAT systems.
- Lightweight design supports rapid cycle times and reduces wear on robotic arms compared to rigid grippers.
- IO-Link soft gripper interface enables straightforward integration with both new and existing robot controllers.
- Industrial grade build tailored for high-mix environments demanding gentle handling and consistent performance.
Comparison and Benefits:
- Versus rigid grippers, Centric Gorilla Finger Actuator minimizes risk of surface damage on soft, brittle, or variable-shaped items.
- Best suited for compliant gripping applications where part size, shape, or material sensitivity excludes traditional grippers.
- Internal pressure control adapts grip force to maintain security without overtightening sensitive products.
Applications:
- Pick-and-place tasks for fragile or deformable goods
- Palletizing irregular consumer products
- Machine tending in lines handling mixed batch sizes
- Sorting, packaging, or assembly requiring compliant and adaptive grasping
How to Use and When to Choose:
- Install the SoftGripping Centric Gorilla Finger Actuator on the robot’s end-of-arm interface; no dedicated mounting base required for most systems.
- Connect via IO-Link or Modbus TCP to compatible controllers for real-time grip adjustments.
- Select this pneumatic gripper for process lines handling products where gripping force must adapt to surface or geometry variations.