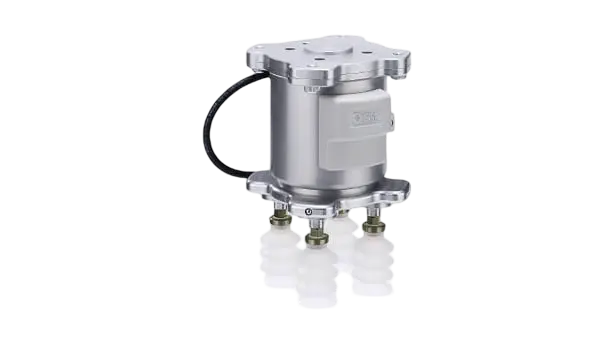
SMC ZXP-X1 Vacuum Gripper for Cobots:
SMC ZXP-X1 is a robot vacuum gripper engineered for collaborative robots in pick-and-place, packaging, laboratory automation, and lightweight assembly tasks.
- Load Capacity: 7 kg
- Vacuum Pressure: −84 kPa
- Device Weight: 0.84 kg
- Mounting Interface: ISO 9409-1-50-4-M6
Applications:
SMC ZXP-X1 suits packaging, machine tending, pick-and-place, and laboratory automation involving Universal Robots and comparable cobot platforms. Smart sensors monitor vacuum levels for process control in automated material handling conditions.
Integration and Setup:
- Plug-and-play via standard M8 connector and single compressed-air tube.
- Fast mounting to Universal Robots or other ISO 9409-1-50-4-M6 interface cobots.
- Modular suction pads adapt for flat, curved, porous, and fragile materials.
- All-in-one design with ejector, air supply and release valves, pressure sensor and pad pre-assembled for rapid deployment.
Competitive Advantages:
- Integrated sensors and compact assembly reduce installation time versus separate vacuum grippers.
- Flexible suction pad selection broadens application range in robotic pick-and-place operations.
- Low device weight (0.84 kg) minimizes impact on robot payload capacity.
- Direct ISO interface for Universal Robots yields broader compatibility and fewer adaptation parts required.
Comparison with Similar Vacuum Grippers:
- SMC ZXP-X1: 7 kg load, −84 kPa vacuum, ISO 9409-1-50-4-M6 mount, fully integrated assembly.
- Competitor A: 5 kg load, −75 kPa vacuum, requires external sensors and valves, limited pad options.
- Competitor B: 8 kg load, −90 kPa vacuum, heavier assembly (1.2 kg), fewer mounting interfaces supported.
Material and Operating Attributes:
- Construction: Industrial-grade polymer housing with modular elastomer suction pads.
- Operating Temperature Range: 5°C to 50°C.
- Typical Response Time: Under 0.5 seconds from signal to vacuum activation.
Installation and Troubleshooting Guide:
- Installation: Attach SMC ZXP-X1 to robot arm using ISO 9409-1-50-4-M6 interface. Connect compressed-air supply and M8 signal cable. Secure modular pad for material type.
- Configuration: Check sensor signal and vacuum pressure settings via robot controller. Test grip on material to verify pad suitability.
- Maintenance: Clean suction pads regularly. Inspect connectors for leaks. Replace pad if grip performance declines.
- Troubleshooting: If vacuum level drops, verify air supply line, valve operation, and sensor readout. Replace damaged pads or connectors as needed.
FAQ:
- Is SMC ZXP-X1 compatible with cobots? Yes, SMC ZXP-X1 integrates with Universal Robots and most collaborative robot platforms via ISO 9409-1-50-4-M6.
- What surfaces can SMC ZXP-X1 vacuum gripper handle? Modular pads enable gripping of flat, curved, porous, and delicate materials.
- How do you install the SMC ZXP-X1? Attach to robot arm with ISO interface, connect air and signal lines, and select pad for material type.
- What is the operating temperature range? The device operates from 5°C to 50°C.
- How do you maintain the gripper? Clean pads, check connector seals, replace pads if suction drops.
- How fast is the SMC ZXP-X1 response? Typical response time is under 0.5 seconds.
- Does SMC ZXP-X1 have certifications? For certification details, refer to SMC documentation and local compliance guidelines.
- Is warranty included? Warranty coverage is determined by distributor and SMC warranty policy; check at point of purchase.