
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SMC
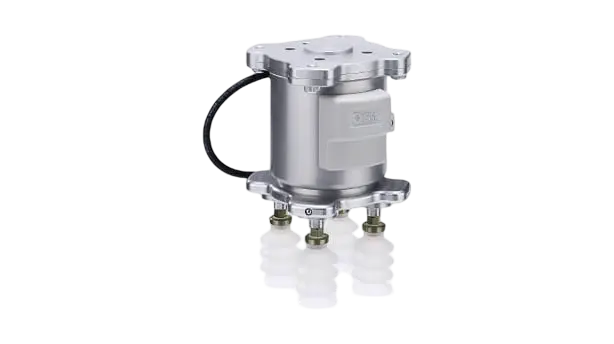
SMC ZXP-X1 is a compact pneumatic vacuum gripper for cobots and Universal Robots, rated for 7 kg payload at 84 kPa vacuum pressure. It integrates an ejector, release valve, and pressure sensor in one unit, connecting via a single compressed-air line and M8 electrical connector to ISO 9409-1-50-4-M6 mounting. Plug-and-play setup enables fast deployment on UR and compatible cobot arms for pick-and-place, packaging, and assembly across electronics, food handling, and logistics applications.
SMC ZXP-X1 is a pneumatic robot vacuum gripper engineered for collaborative robots and Universal Robots in automation applications including pick-and-place, packaging, and assembly across electronics, food handling, and logistics.
SMC ZXP-X1 mounts directly via ISO 9409-1-50-4-M6, enabling seamless integration with Universal Robots and other collaborative robot platforms. This robot vacuum gripper suits flexible and modular production lines needing quick changeovers and high payload capacity.
SMC ZXP-X1 vacuum gripper is used by manufacturers, logistics providers, and laboratories for fast pick-and-place, lightweight packaging, and precise assembly. Common uses include electronics assembly, food handling, and clean gripping of varied parts.
The SMC ZXP-X1 is a compact pneumatic vacuum gripper designed for collaborative robots handling flat, curved, and porous parts. Choose this over mechanical or electric parallel grippers when you need to grip delicate or varied surfaces without marring, or when you want to minimize wrist payload and downtime on UR and cobot platforms.