
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SMC
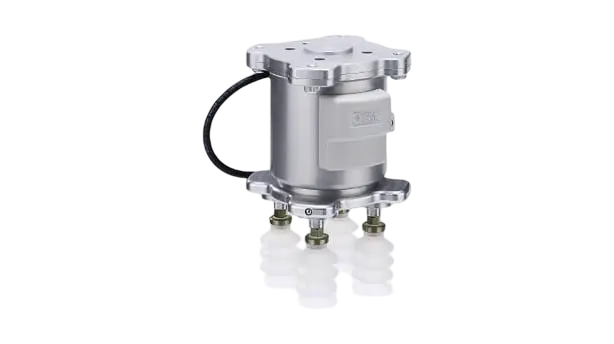
Modular vacuum gripper for collaborative robots, with integrated ejector and pressure regulation. Lifts 7 kg at 84 kPa vacuum with 17 L/min flow rate. Mounts via ISO 9409-1-50-4-M6 interface to UR, Techman, FANUC, and Yaskawa robots. Interchangeable suction pads in flat, bellows, or thin-flat profiles; choose silicone, NBR, or urethane for pick-and-place, packaging, electronics assembly, and lab automation. Single M8 connector and compressed-air tube for quick setup.
SMC ZXP-X1 Vacuum Gripper is a modular robot vacuum gripper end effector designed by SMC for precise handling in pick-and-place, packaging, electronics assembly, and laboratory automation environments.
The SMC ZXP-X1 mounts universally via ISO 9409-1-50-4-M6, compatible with many collaborative robot brands. Learn more in our robot arms category.
For parts with varied shapes or surfaces, see vacuum pad options or our guide to selecting vacuum pads.
SMC ZXP-X1 is a robot vacuum gripper end effector from SMC, designed for cobots in industrial automation, linking to Universal Robots, Omron/Techman, FANUC, and Yaskawa through the ISO 9409-1-50-4-M6 interface.
The SMC ZXP-X1 is a vacuum-based end effector designed for delicate, flat, or smooth parts where mechanical jaws risk damage or marks. It contrasts with two-finger or parallel grippers, which excel at grasping irregular or robust items.