
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SMC
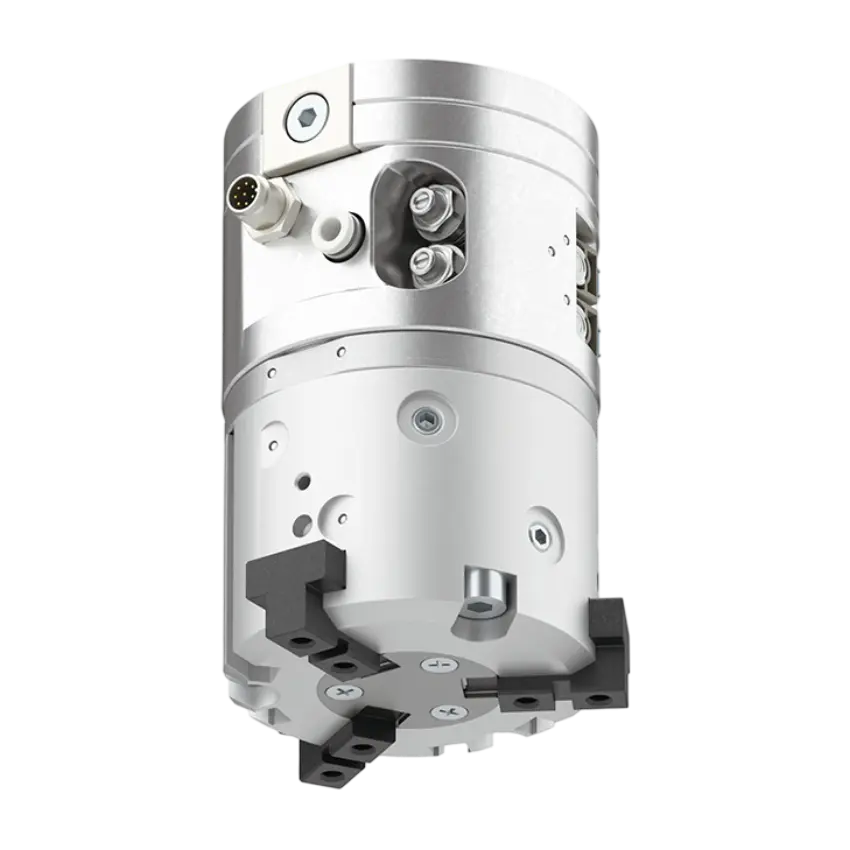
The SMC RMHS3 is a 3-finger pneumatic gripper for collaborative robots, delivering 130 N internal gripping force with 0.01 mm repeatability. It handles cylindrical and irregular workpieces up to 2.4 kg and connects via a single air line and 24 VDC cable. Pre-configured for ABB Gofa, the RMHS3 mounts directly to 12+ cobot platforms including Universal Robots, FANUC, YASKAWA, KUKA, and Omron Techman using the ISO 9409-1-50-4-M6 interface.
SMC RMHS3 Pneumatic Gripper is a three finger pneumatic gripper engineered for collaborative robots in pick-and-place, machine tending, and flexible automation tasks.
Model RMHS3-40D-121P-DE delivers stable axial gripping for cylindrical and irregular parts and operates with repeatability of ±0.01 mm. Its three finger centric design secures test tubes, bar stock, bottles, and circular workpieces typical in laboratory and production environments.
The SMC RMHS3 is a three-finger pneumatic gripper for cobots, chosen when you need low-cost, simple pneumatic control with minimal air consumption. It compares to electric grippers (higher upfront cost, no air supply needed) and magnetic grippers (work only on ferrous parts).