
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SMC
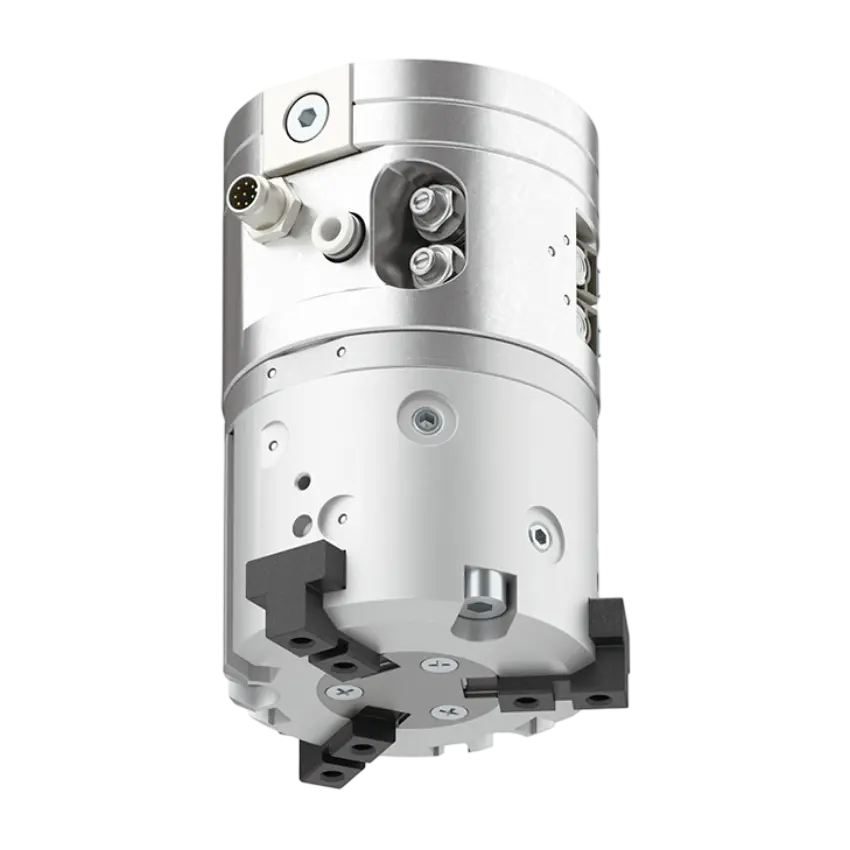
SMC RMHS3 pneumatic 3-finger gripper for collaborative robots. Delivers 130 N internal gripping force with 8 mm stroke and 0.01 mm repeatability, ideal for centric gripping of cylindrical and irregular workpieces. Integrated solenoid valve, auto switch, and fittings simplify setup to a single air tube and electrical cable. Includes manual tool changer for fast swaps. Compatible with Universal Robots, FANUC, YASKAWA, KUKA, ABB, and 8+ other cobot platforms.
The SMC RMHS3 Pneumatic Gripper 3-Finger is an industrial pneumatic 3 finger gripper engineered for centric gripping of cylindrical and irregular parts on collaborative robots in automation, laboratory, and assembly applications.
The SMC RMHS3 is a pneumatic 3-finger gripper designed for centered gripping of cylindrical and irregular parts. Choose it over 2-jaw parallel grippers when part centering and balanced radial force matter, and over traditional multi-tube pneumatic systems when you need simplified integration.