
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SMC
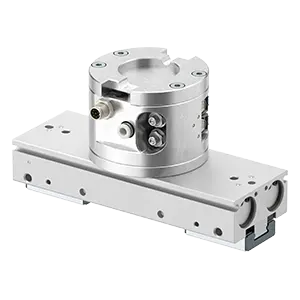
SMC RMHF2-16D2-011P-DE is a 2-finger pneumatic parallel gripper built for collaborative robots. It delivers 32 mm stroke per jaw, 90 N gripping force, and 0.1 mm repeatability for precise part handling up to 2 kg. Integrated solenoid valve and single air supply simplify installation. Manual tool changer interface fits Universal Robots, FANUC, and DENSO cobots.
SMC RMHF2-16D2-011P-DE is an industrial pneumatic parallel gripper designed as a cobot end effector for precise part handling in automation cells, compatible with collaborative robots from Universal Robots, FANUC, and DENSO.
The SMC RMHF2 is a pneumatic parallel gripper best chosen when you need reliable gripping force on diverse part geometries without requiring vacuum or magnetic surfaces. Compare it to vacuum grippers for non-porous parts or magnetic chucks for ferrous materials.