
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SMC
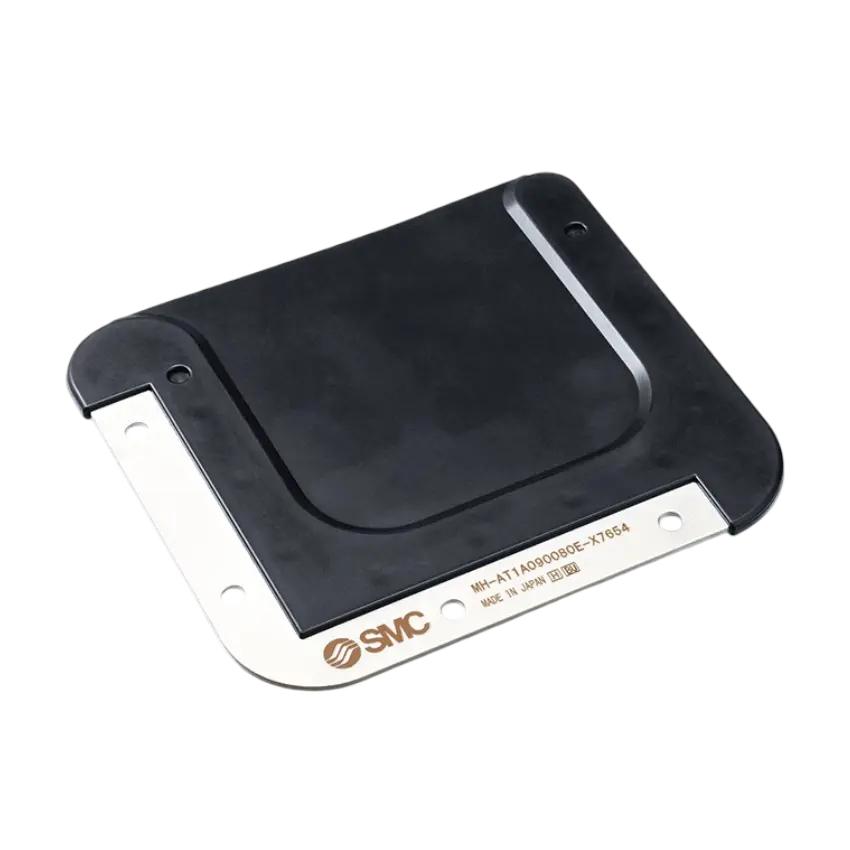
Soft gripper finger for SMC MH-series air grippers. Flexes to grip irregular shapes and protects delicate items. Choose EPDM for -20 to 150°C or silicone for -30 to 200°C. FDA-compliant for food, electronics, and fragile parts. Mounts via stainless steel plate.
SMC MH-X7654 Soft Gripper Finger is a flexible robot gripper finger for SMC MH-series air grippers, engineered for delicate part handling in food-safe, electronics, and packaging automation environments.
SMC MH-X7654 supports gentle, adaptive handling for irregular, fragile, or sensitive parts where avoiding product damage is critical. The soft gripper finger reduces breakage and surface abrasion, making it ideal for gripping bottles, cans, packaged food, or electronics components in high-mix operations. FDA-related compliance enables food-safe gripper installations.
Manufactured using EPDM or silicone rubber, the MH-X7654 offers high abrasion resistance and flexibility with robust cycle life. Both material options satisfy FDA-related requirements for handling sensitive products.
Quick installation via stainless-steel mounting plate allows two orientations for the best fit and alignment. SMC MH-X7654 is compatible with SMC MH-series air grippers and soft gripper accessories. Explore other SMC MH-series soft grippers, end effectors, and application guides in the End Effectors & Tooling category or Soft Grippers guide for related solutions.
SMC MH-X7654 is the preferred choice when fragile or irregular parts require gentle, food-safe gripping with enhanced chemical and temperature resistance. Compatible with SMC MH-series and suitable for precision tasks where product damage must be minimized.
The SMC MH-X7654 is a soft rubber finger attachment for air grippers, chosen over rigid metal jaws when parts are fragile, irregularly shaped, or require food-safe contact. Rigid fingers apply point pressure and risk breakage; soft fingers conform and distribute grip force across the workpiece surface.