
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SCHUNK GmbH & Co. KG
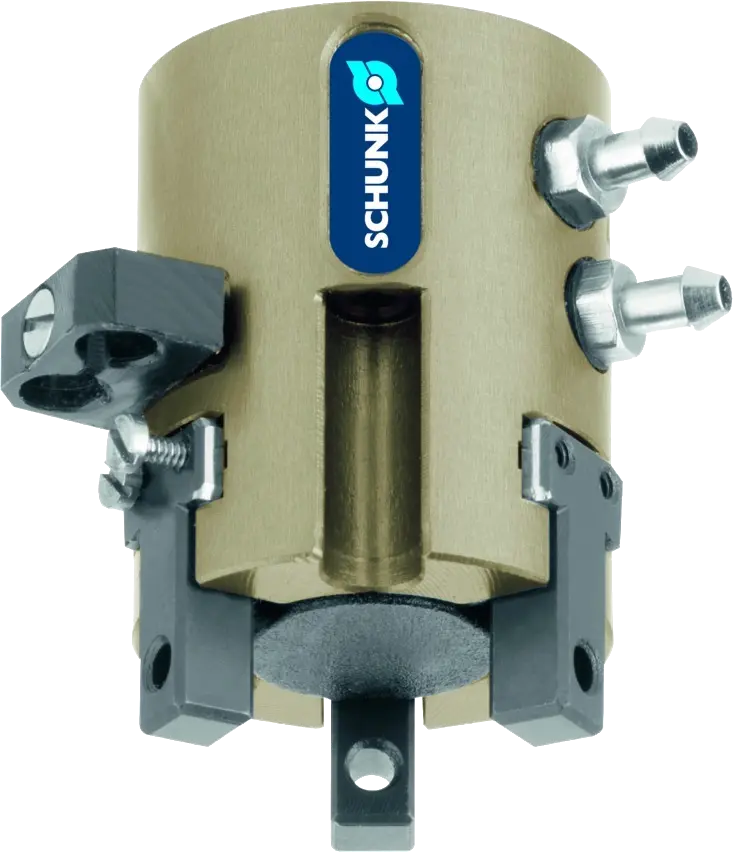
SCHUNK 340480 pneumatic three-finger gripper for miniature parts. Delivers 50 N grip force with 1 mm stroke per jaw, 0.01 mm repeatability, and 0.01 kg weight. Ideal for electronics assembly, lab automation, and precision pick-and-place of delicate components up to 0.05 kg.
SCHUNK 340480 is a pneumatic 3-finger gripper designed for precision gripping and manipulation of small parts in industrial automation, electronics assembly, and laboratory automation.
SCHUNK 340480 mini gripper is optimized for use in precision pick-and-place tasks, industrial robots, and automated systems requiring reliable centric gripping of small or delicate components. The lightweight design and 1 mm stroke per jaw make it ideal as a precision gripper for electronics assembly and laboratory handling where repeatability down to 0.01 mm is important. Direct air supply or screw fittings enable straightforward system integration, and the gripper is suitable for workpiece temperatures up to 90°C.
For robot grippers optimized for delicate or round components, the SCHUNK pneumatic 3-finger gripper delivers accuracy and reliability in compact installations.
SCHUNK 340480 mounts to compatible SCHUNK end effectors and integrates with most pneumatic systems. For more compact or specialized grippers, see the pneumatic gripper and end effectors categories. System integrators can also consider alternative SCHUNK 2-finger grippers or electric grippers as needed.
Choose this 3-finger pneumatic gripper when you need centric, stable gripping of small cylindrical or round parts. The 3-finger design centers workpieces evenly, while 2-finger grippers apply force from opposite sides and suit flat or rectangular components.