
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
Camozzi Automation GmbH
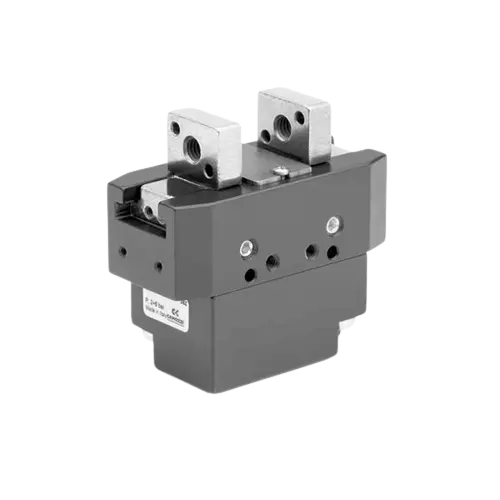
Camozzi CGSP parallel gripper. Pneumatic, self-centering end effector. 70 N gripping force, 0.02 mm repeatability, 0.051 kg. Compact design for precision pick and place, feeding, and assembly of small components in electronics, medical devices, cosmetics, and food packaging.
Camozzi CGSP Parallel Gripper is a pneumatic parallel gripper engineered for precision gripping and delicate automation tasks in environments such as electronics assembly, cosmetics manufacturing, medical device production, and food packaging lines.
The CGSP series combines a self-centering T-guide jaw mechanism and pneumatic actuation to deliver high precision and stability. Designed for compact installation, the low mass supports fast cycle times and sensitive handling of small and fragile objects.
The parallel gripper features corrosion-resistant surface coating, with seals constructed from wear-resistant elastomer material. The robust housing provides protection against dust and contamination, making it suitable for demanding industrial settings.
Suitable for pick and place operations, feeding systems, and machine loading tasks, the Camozzi CGSP Parallel Gripper adapts to automation cells where repeatable accuracy and cleanroom compatibility are key.
Each CGSP variant can be integrated with standard mounting interfaces for pneumatic end effectors. Jaw width, operating pressure range, air consumption, and electrical requirements are detailed in the specification table for direct comparison by buyers.
The Camozzi CGSP series includes four individual stroke sizes for selection depending on object dimensions and gripping force requirements. For additional details, refer to the size comparison matrix and specification list.
The Camozzi CGSP is a compact pneumatic parallel gripper optimized for precision and speed, offering an alternative to manual pick-and-place, vacuum systems for non-porous parts, or larger industrial grippers where force and repeatability matter on delicate, small objects.