
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
Schmalz
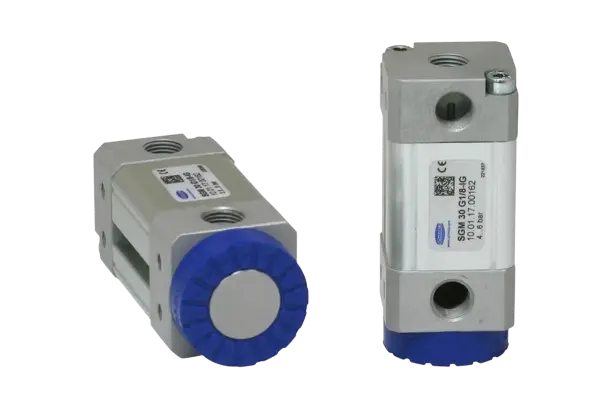
Schmalz SGM 30 pneumatic magnetic gripper with 35 N holding force for ferromagnetic sheets and metal components. Permanent-magnet design maintains grip during power loss; pneumatic plunger releases workpieces. 0.13 kg, G1/8 thread mount, operates to 70°C. Integrated electronics and status signals. Compact design for sheet-metal handling, loading cycles, and bin-picking.
Schmalz SGM 30 Pneumatic Magnetic Gripper is a permanent-magnet end effector designed for robotic pick-and-place and handling of ferromagnetic workpieces in sheet-metal, bin-picking, and automated loading applications.
Pneumatic actuation triggers the release of the workpiece. The permanent-magnet design maintains holding force even during a power loss, making the SGM 30 suitable for safety-critical environments. Controlled demagnetization is supported by integrated electronics to ensure precise release when required.
The Schmalz SGM 30 magnetic gripper integrates easily with robot flanges or custom mounting plates. Standard pneumatic connections and the G1/8 female thread simplify installation on a wide range of automation systems.
For detailed specifications, compatibility checks, or consultation on suitable end effectors for your automation system, review the technical datasheet or contact our engineering team. Explore related grippers and end effectors for alternative solutions.
Choose the SGM 30 when you need reliable handling of steel and iron workpieces without continuous power draw or the risk of losing grip during a power failure. It combines magnetic holding with pneumatic-triggered release for fast, safe pick-and-place in compact cells.