
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
FORMHAND Automation GmbH
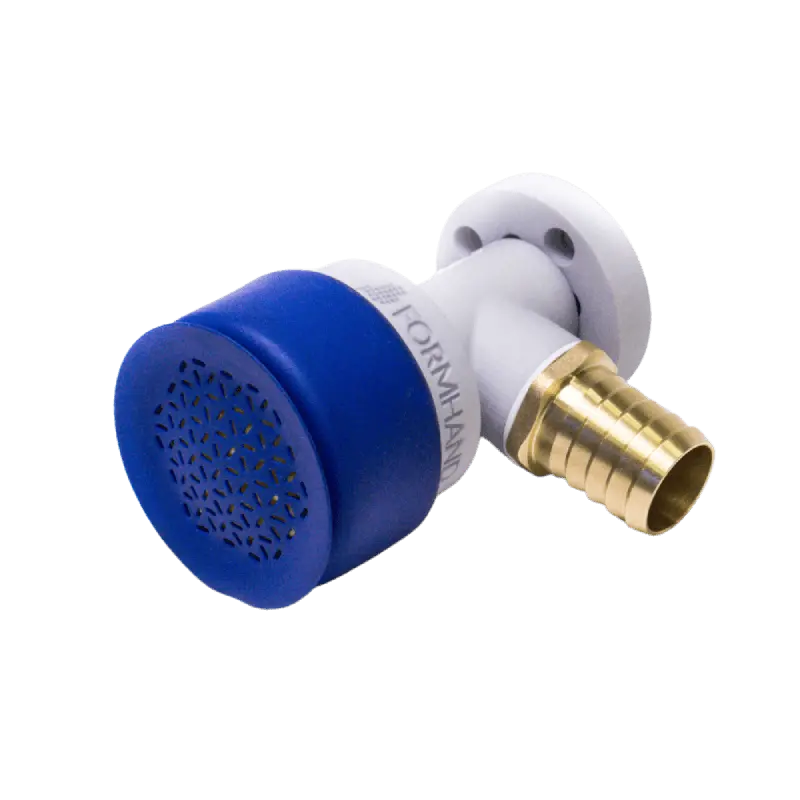
Pneumatic soft gripper with granulate-filled cushion that conforms to irregular object shapes. 8 cm gripping surface handles complex geometries without tooling changes. Maximum payload 2 kg, weighs 0.45 kg. Designed for collaborative robots in machine tending and intralogistics.
The FORMHAND Soft Gripper, Pneumatic, 2 kg is a flexible gripper for industrial and collaborative robot applications, designed to handle variable shapes and complex surfaces in machine tending and intralogistics.
The FORMHAND soft gripper utilizes a granulate-filled cushion for a customizable, conformable surface. The pneumatic soft gripper design adjusts to a wide range of geometries, decreasing the need for tooling changes and minimizing changeover time in workflows involving irregular or delicate components.
Specifically engineered for collaborative robot gripper setups, the FORMHAND model is suited for cobots in machine tending and logistics environments. The soft gripper for cobots adapts to mixed-part handling without sacrificing reliability.
Buyers can select the FORMHAND Soft Gripper, Pneumatic, 2 kg as a standalone flexible gripper module or as part of a complete cobot bundle with hose module, suction module, and pneumatic ejector included. The bundle simplifies installation for pneumatic gripper applications requiring quick start-up in collaborative settings.
Unlike conventional rigid gripping tools, the FORMHAND soft gripper reduces dedicated tooling requirements by adapting its cushion to variable shapes. This feature shortens changeover times compared to standard grippers and can support workflows with frequent geometry changes.
The adaptable cushion on the FORMHAND Soft Gripper is filled with proven granulate material, offering gentle and reliable contact with sensitive parts. FORMHAND Automation prioritizes safety in the pneumatic soft gripper design for collaborative robot compatibility.
The FORMHAND Soft Gripper, Pneumatic, 2 kg is optimized for collaborative robot brands used in machine tending and logistics, including cobots equipped with standard pneumatic interfaces. Check FORMHAND’s compatibility list for integration guidelines across supported collaborative robots.
The FORMHAND Soft Gripper is a pneumatic end effector designed for collaborative robots that need to handle mixed part shapes and delicate surfaces without dedicated tooling per geometry. It contrasts with rigid parallel or specialty grippers that require tool changes or separate jaw designs for each part family.