
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
Effecto Group SpA
Electric parallel gripper for collaborative robots with adjustable grip force, real-time feedback, and Modbus RTU control. Compact 1.5 kg design with brake locking and part detection for precision handling in manufacturing and assembly.
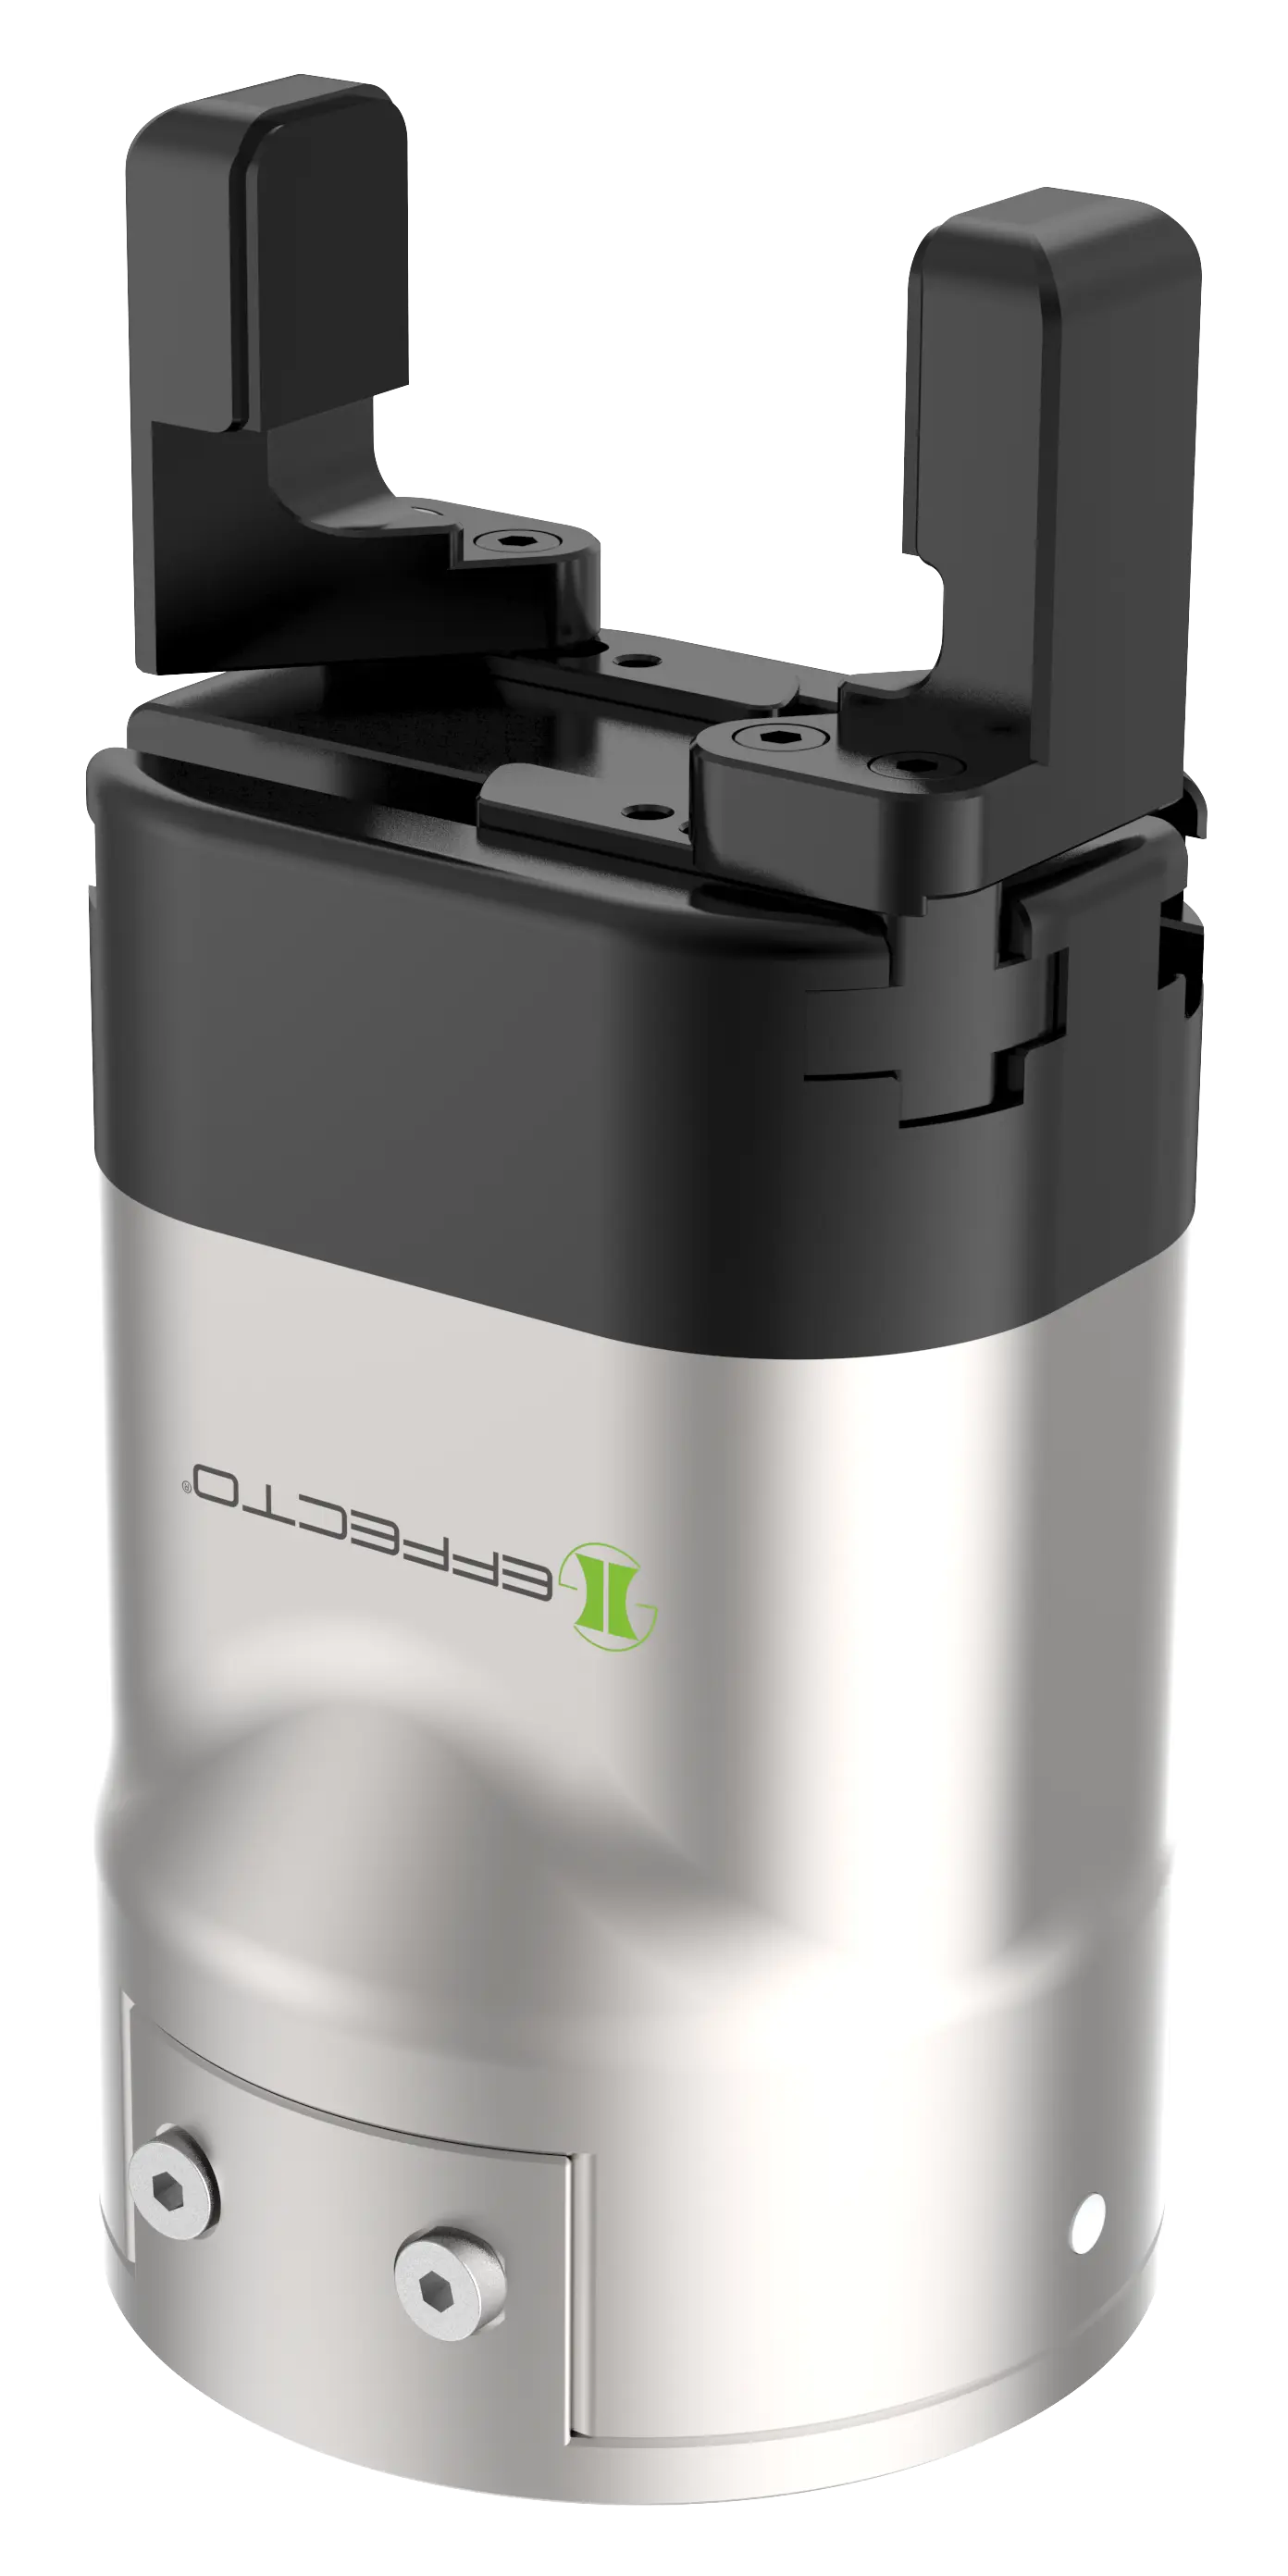
The Effecto ECG2-30300 is an electric parallel gripper with two fingers designed for collaborative robots in automation environments, ideal for precision handling in manufacturing, electronics assembly, and logistics.
The ECG2-30300 parallel gripper provides precise and reliable gripping for collaborative robot arms used in tasks such as pick-and-place, palletising, machine tending, and electronics assembly. Its embedded controller and brake locking mechanism deliver consistent performance in harsh industrial conditions.
The ECG2-30300 is suitable for robots requiring high-cycle performance and sensitive data feedback. Adjustable settings allow for custom grip force and position, making it a strong choice for applications needing repeatability and safe interaction.
Users report reliable operation and easy integration for collaborative robot gripper applications in automation environments.
The Effecto ECG2-30300 is an electric two-finger gripper designed for collaborative robots, where it competes with pneumatic alternatives and heavier traditional grippers. Choose it when you need quiet, feedback-rich automation in shared workspaces or tight cell layouts.