
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
Dobot Robotics
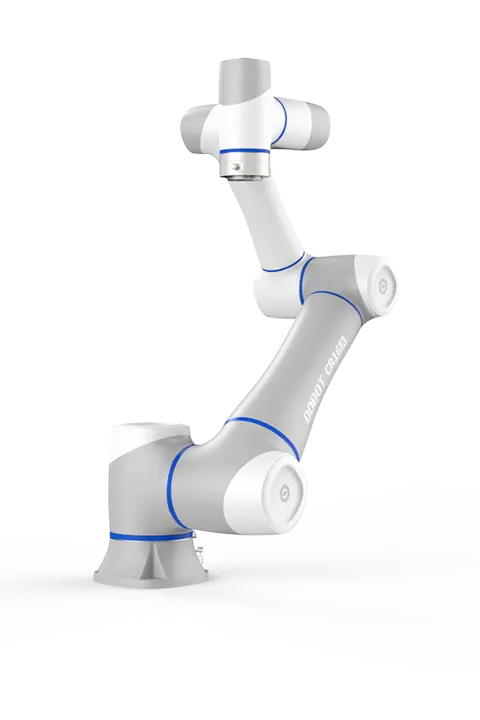
Six-axis collaborative robot arm with 16 kg payload capacity and 1000 mm reach, delivering ±0.03 mm repeatability for precision automation. IP54-rated for industrial environments, it supports multiple communication protocols including Modbus TCP, Ethernet/IP, and PROFINET. Ideal for assembly, palletizing, machine tending, and material handling tasks where human-robot collaboration is required.
The DOBOT CR16A is an industrial collaborative robot arm with six articulated axes designed for heavy-duty manufacturing, research, and automation applications. Engineered for use alongside human operators in industrial settings, the CR16A offers high payload capacity and seamless integration with modern control systems.
DOBOT is a recognized manufacturer of robotic automation solutions, with the CRA series optimized for flexibility, advanced safety, and user-focused programming. The CR16A model employs high-performance harmonic drive reducers and highly integrated joints to deliver rapid cycle times and smooth motion, reflecting DOBOT’s commitment to precision and reliability.
The DOBOT CR16A supports advanced integration via multiple protocols, including DobotStudio, DobotLink, Modbus, TCP/IP, Ethernet/IP, ROS, and PROFINET, making it compatible with a wide range of industrial PLCs and HMIs. Users benefit from graphical programming, drag-to-teach, and scripting options, suitable for both expert technicians and operators with minimal robotics experience.
Compared to the CR5 and CR10 models, the CR16A offers increased payload and a robust structure tailored to demanding material handling requirements in industrial environments. The 38 kg weight and 16 kg payload address tasks where smaller cobots are insufficient.
The CR16A bridges the gap between small-payload cobots and heavy fixed gantries. Choose it when you need a collaborative robot that can handle substantial parts without sacrificing flexibility or ease of programming.