
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SCHUNK GmbH & Co. KG
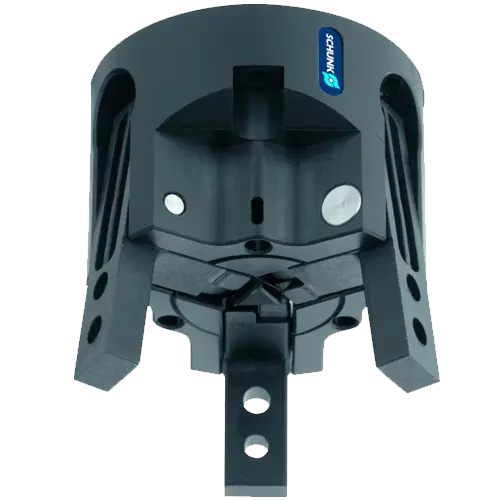
SCHUNK 305204 pneumatic 3-finger gripper delivers 329 N gripping force with 0.1 mm repeatability for precise handling of small components up to 0.3 kg. Compact, lightweight design supports internal and external gripping in small-part assembly, pick-and-place, and feeding applications.
SCHUNK Gripper 305204 is a compact pneumatic 3-finger gripper engineered for small part handling, centric alignment, and automated precision assembly tasks involving lightweight workpieces up to 0.3 kg.
SCHUNK Gripper 305204's centric 3-finger design offers superior alignment for round workpieces compared to parallel grippers, which are optimal for rectangular or block-shaped items. The compact form factor distinguishes it from other heavier 3-finger pneumatic grippers, making it suitable for space-constrained robot cell layouts.
The SCHUNK 305204 is a compact pneumatic 3-finger gripper built for round and rotationally symmetric workpieces up to 0.3 kg. It differs from parallel grippers, which grip flat or rectangular parts, and from vacuum grippers, which require non-porous surfaces. Choose this design when you need centric alignment and repeatable positioning on round stock.