
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
IPR – Intelligente Peripherien für Roboter GmbH
Pneumatic 2-jaw parallel gripper with roller guide for precision handling. Delivers 140 N gripping force, 0.01 mm repeatability, and 12.7 mm stroke per jaw. Operating range 1.5 to 8 bar, cycle time 0.36 seconds, rated to 80 degrees C. Suitable for high-throughput assembly and positioning tasks.
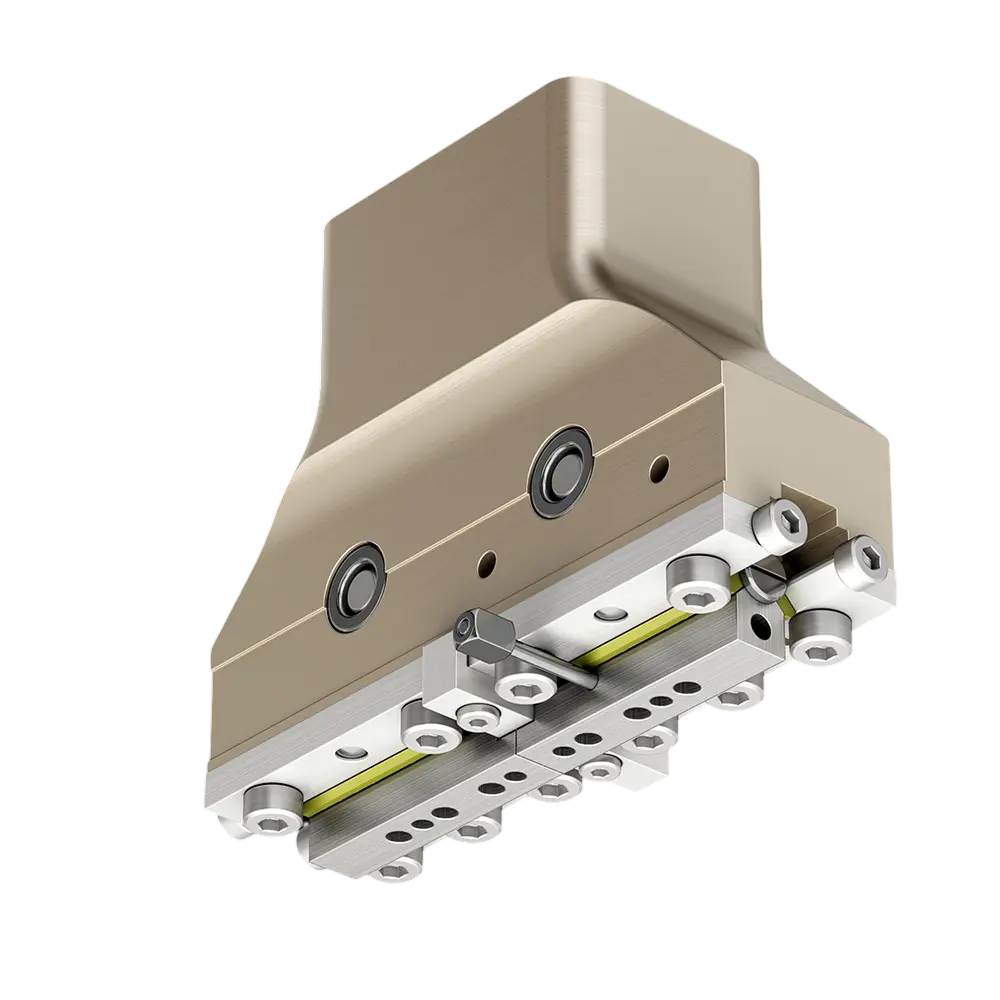
IPR RP Series pneumatic parallel gripper is a roller guide two-jaw end effector engineered for precision handling in automated industrial environments, including electronics assembly, medical device handling, and precision machining.
For integration, the RP Series can be mounted on robot arms using standard pneumatic interfaces. Applications requiring high cycle speeds benefit from a 0.14 second opening and closing time.
Suitable for industrial robots needing a compact pneumatic parallel gripper for precision, repeatability, and fast cycle times.
Select the RP-100-I for tasks demanding high repeatability (0.01 mm) and moderate gripping force (140 N) when workpiece weight is up to 0.2 kg and the application requires smooth, low-friction operation. The roller guide mechanism outperforms standard parallel grippers in wear resistance and precision, making it ideal for high-throughput environments.
Compared to standard parallel grippers, the roller guide design in the IPR RP Series reduces maintenance needs and delivers higher accuracy by minimizing jaw play. For applications where increased friction or frequent calibration is a concern, the roller guide is preferable. Pneumatic actuators are a suitable accessory for reliable operation, and finger extensions are available for adapting to custom part geometries.
Contact us for maintenance accessories and guidance on troubleshooting jaw movement deviations or grip inconsistencies.
Share experiences or see industry case studies for RP-100-I application success in precision robotics.
The IPR RP Series is a compact pneumatic parallel gripper built around a roller guide mechanism, making it suited for high-speed, precision pick-and-place work where jaw smoothness and repeatability matter. Choose it over standard parallel grippers when cycle speed, tight positioning, and low maintenance are priorities.