
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
IPR – Intelligente Peripherien für Roboter GmbH
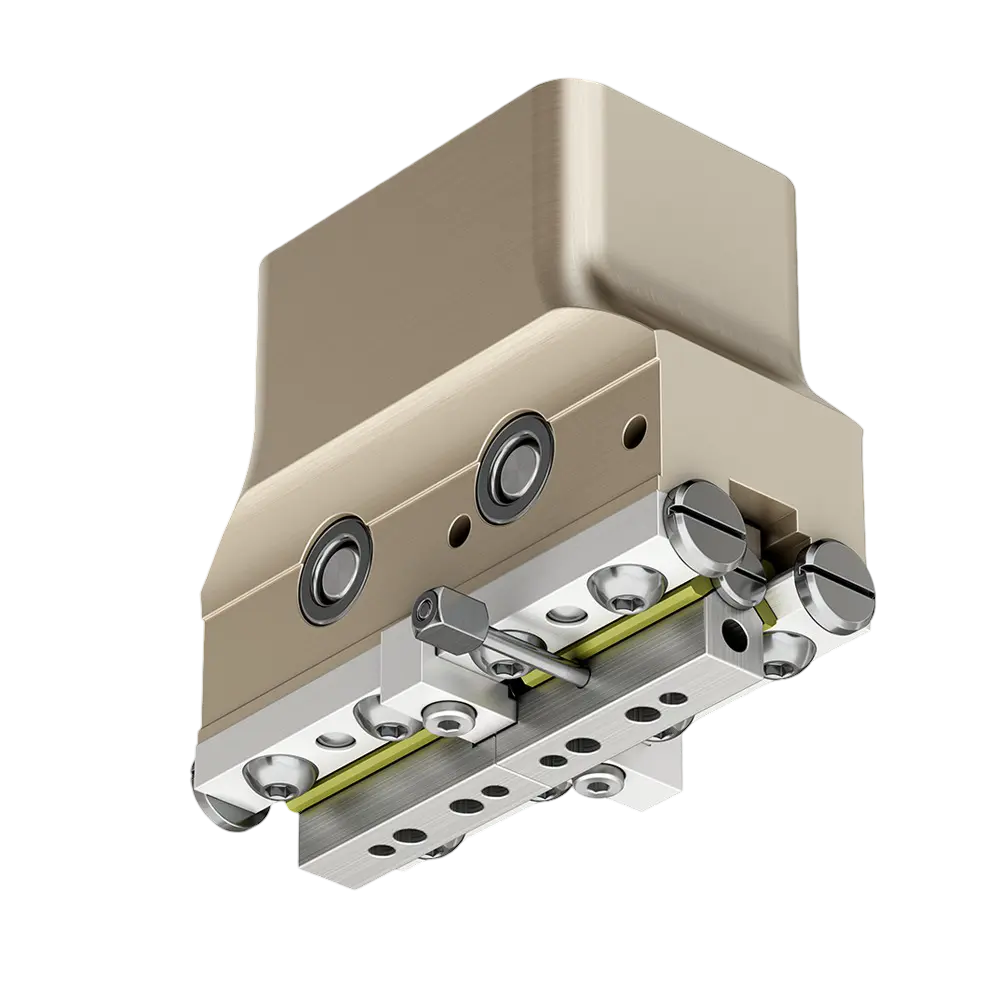
Compact pneumatic parallel gripper with 90 N gripping force and 0.01 mm repeatability. Roller guide system reduces friction for precise jaw control and fast cycle times (0.14 s), ideal for small parts handling and precision assembly where space and speed matter.
IPR RP Series parallel gripper RP-50-I is a pneumatic parallel jaw gripper engineered for precision handling in automated systems, suitable for small parts assembly and laboratory automation.
The RP-50-I parallel jaw gripper utilizes a roller guide system to ensure accurate, low-friction jaw movement. The rack and pinion drive, combined with roller bearing guidance, delivers fine control for repeatable positioning. The pneumatic drive operates at 1.5 to 8 bar, supporting cycle times of 0.14 seconds for both opening and closing, which is ideal for high-speed production environments.
Designed by IPR – Intelligente Peripherien für Roboter GmbH, the RP-50-I is part of the RP Series, and is recommended for precision assembly, electronics manufacturing, and situations requiring compact form factor and quick actuation. The parallel jaw configuration compared to angular or 3-finger grippers offers consistent gripping for flat or uniform workpieces, especially when delicate handling is required.
Internal product guides on parallel gripper selection and end effector compatibility are available on the store for further assistance.
The IPR RP Series is a compact pneumatic parallel gripper engineered for high-speed, precision pick-and-place work on small, flat parts. Choose it over electric grippers or multi-finger designs when speed, simplicity, and sub-0.01 mm repeatability matter more than force range or complex grip profiles.