Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
SCHUNK GmbH & Co. KG
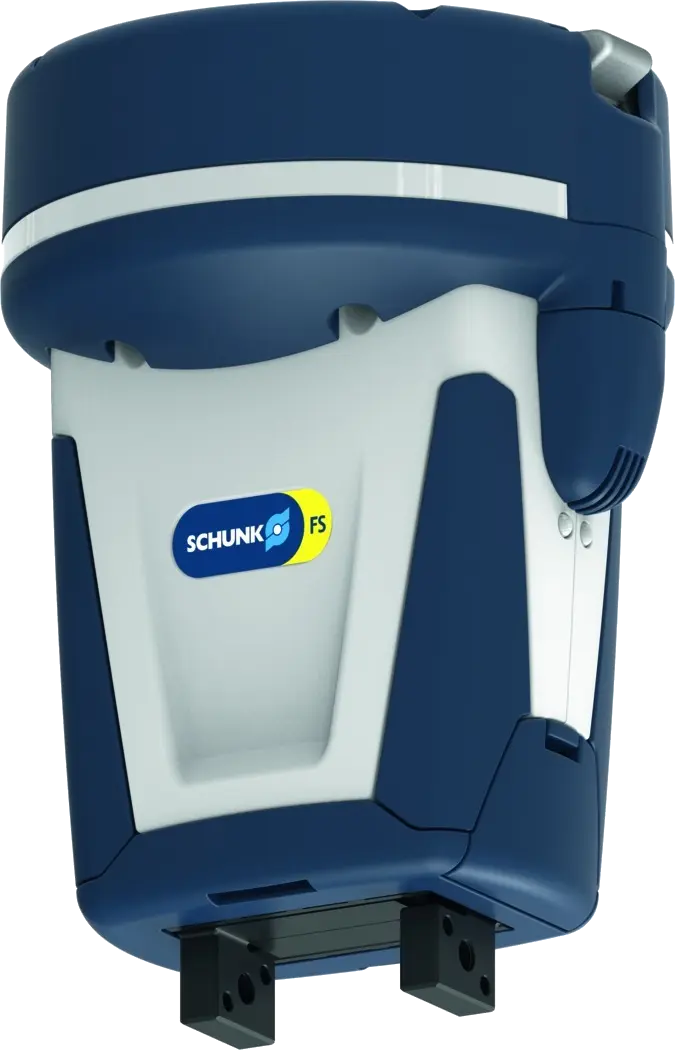
SCHUNK 1441947 electric parallel gripper for collaborative robots. 6 mm stroke per jaw, adjustable grip force to 140 N, 0.02 mm repeatability. Handles parts up to 0.7 kg with collision protection and force limiting for safe shared-workspace operation.
The SCHUNK 1441947 is a precision electric gripper for small parts, designed as a 2-finger parallel gripper for collaborative robots requiring safe, accurate, and reliable part handling.
SCHUNK 1441947 delivers a high force-to-weight ratio for its class and 0.02 mm repeatability, making it suitable where precision, safety, and low-maintenance integration with cobots are required. The 6 mm stroke offers versatility for applications needing gentle but secure gripping. Compared to many electric parallel grippers, SCHUNK's combination of force, safety design, and compactness makes it a cost-effective solution for modern collaborative manufacturing.
The SCHUNK 1441947 belongs to the SCHUNK electric gripper series for collaborative robots and is integrable with a range of compact cobots. For more options, view other electric grippers or see our cobot end effector compatibility guide.
The SCHUNK 1441947 is a compact electric parallel gripper built for collaborative robots handling small, precise components. It sits between pneumatic grippers (which require compressor infrastructure) and magnetic chucks (which work only on ferrous parts). Choose it when you need safe human-robot collaboration, repeatable accuracy, and no ongoing air supply.